AI Engineer · Rainscales · CS Honors, HCMUT

Lê Chí Đại / kaios

I deploy vision models on the edge and build LLM applications with the evaluation that shows whether they work.

At Rainscales I ship real-time detectors as TensorRT engines on NVIDIA Triton and Jetson Orin, with a Qwen3-VL verifier that raised alert precision from 6.6% to 18.7%. I built the CoinSight multi-agent SRE copilot and its fault-injection eval, led the AI backend of VoiceReaderAI, a NAVER Hackathon national finalist, and co-authored MonoBEN (RIVF 2026) at ML4U Lab & AISIN. Next, I want to specialize in LLM inference serving.

AI systems · LLM agents · 2026

CoinSight

92.9% on held-out tests · every injection resisted

A multi-agent SRE copilot for a streaming market-data platform, evaluated by injecting faults and scoring answers against SQL answer keys.

My contributionBuilt the Analyst and Operations agents, A2A delegation behind the MCP gateway, the fault-injection eval and the model benchmark; teammates built the batch warehouse and Airflow scheduling.
LangGraph · A2A · MCP · FastAPI · Kafka/Spark · OpenTelemetryDetailsCode

AI systems · Assistive technology · 2025

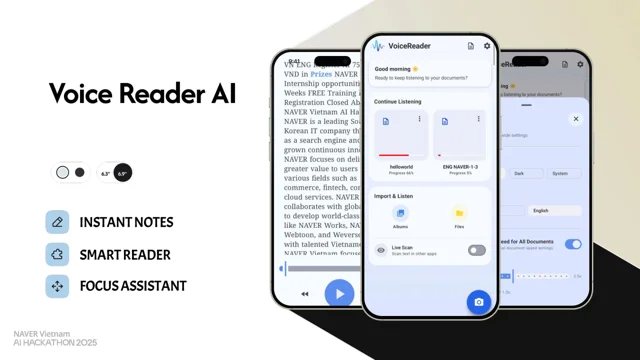
VoiceReaderAI

National finalist · NAVER Vietnam AI Hackathon 2025

Led the architecture and AI backend of an Android reading assistant for ADHD users: OCR, Vietnamese narration with voice cloning, and retrieval-based Q&A. NAVER Hackathon national finalist.

My contributionLed core AI/backend implementation and coordinated end-to-end integration in a four-person team.

Gemini · LangChain · Pinecone · CLOVA OCR / Voice · VieNeu-TTSDetailsProject page

AI systems · Infrastructure · 2026

Talent Intelligence

Architecture and async backend owner · Team of 2

A multi-agent LangGraph backend that parses CVs, scores candidate-job fit, and verifies claims against public sources, with RabbitMQ/Celery workers.

My contributionOwned architecture, parsing/chunking, worker pipeline, and R2/pgvector storage in a two-person team.

FastAPI · Celery · LangGraph · pgvector · RabbitMQDetailsCode

Computer vision · Graphics · 2026

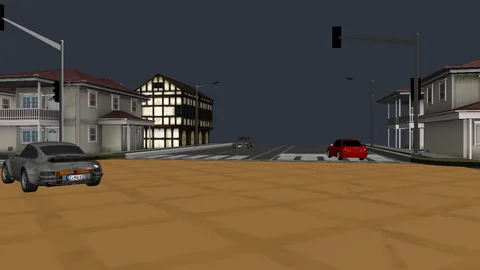
VisionDrive3D

RGB, depth, masks and 3D boxes from one renderer

Co-built an OpenGL renderer for annotated driving datasets and benchmarked YOLOv8, RT-DETR, and Faster R-CNN on accuracy and latency.

My contributionBuilt rendering hooks, annotation exports, and GLSL shaders for RGB, depth, and segmentation outputs.

Python · OpenGL · PyTorchDetailsCodeProject page
  1. Jun 2026–present

    AI Engineer

    Rainscales · Real-time AI detection

    Deploy detectors as FP16 TensorRT engines on NVIDIA Triton with dynamic batching, and run DeepStream on live RTSP feeds across 15 rig fleets, up to 30 concurrent streams per Jetson Orin. Built a second-stage verifier that sends cropped multi-frame evidence to a self-hosted Qwen3-VL, raising alert precision from 6.6% to 18.7% on the test set. Extended red-zone rules to 360° fisheye cameras with ego-motion compensation.

  2. Apr–Jun 2026

    AI Intern

    AKTech · Marker-free multi-camera calibration

    Co-developed a service that calibrates multi-camera rigs from a person’s T-pose instead of a checkerboard. Implemented pose-based RANSAC initialization and confidence-weighted Ceres bundle adjustment.

  3. 2025–present

    Research Assistant (part-time)

    ML4U Lab & AISIN

    Added camera-intrinsic embeddings to monocular 3D detection, improving KITTI AP_3D Hard from 20.80 to 21.13. Co-author of “MonoBEN: Monocular 3D Object Detection Beyond Fixed Camera iNtrinsics”, accepted for presentation at RIVF 2026 (IEEE).

  4. 2025

    ZALO AI Challenge — AeroEyes

    Synthetic data generation for few-shot aerial object detection.

  5. 2023–25

    HCMUT merit scholarships

    Five consecutive semesters · GPA 3.9/4.0.

03 · Interactive

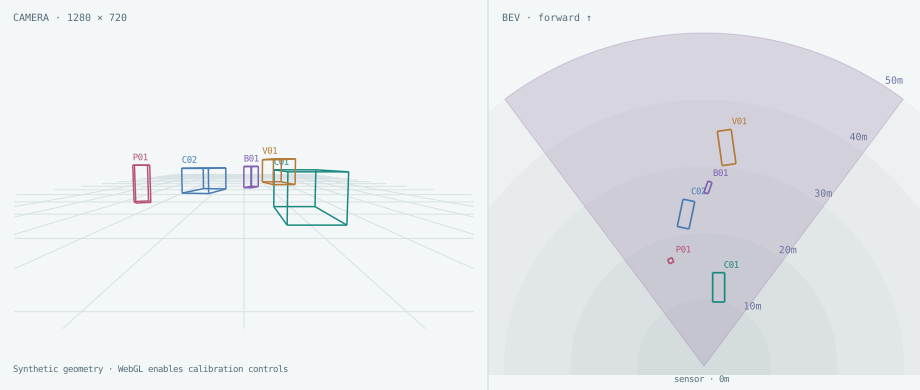
3D detection & camera geometry

Calibrate a camera. Inspect projected boxes and their bird’s-eye footprints.

Synthetic camera projection beside a sensor-centered bird’s-eye view with metric range rings and oriented box footprints.Static preview

Car 01 · 4.4 × 1.8 × 1.6 m

Camera calibration · K, R, T
Intrinsics K

Image plane: 1280 × 720 px

Rotation R

Optical-axis rotations → valid R

Translation T

World → camera, not camera position

Projection math & coordinate conventions

p_camera = R p_world + T · λ [u, v, 1]ᵀ = K p_camera

K
R
T (m)

World: X forward, Y left, Z up. Optical camera: x right, y down, z forward. The BEV is sensor-centered, with the horizontal optical-axis direction pointing up; rings measure ground-plane distance from the sensor. The shaded sector is the angular envelope of the image-corner rays in BEV, not the frustum’s intersection with the ground. C = −RᵀT is the camera position in world coordinates.

Rotation controls compose as R = Rz(roll) Rx(pitch) Ry(yaw) R₀, where R₀ maps the world axes to the optical frame. No lens distortion is modeled. Cuboid edges are clipped at z = 0.1 m before projection.

Synthetic boxes and pinhole geometry—not detector predictions or research results. Built with Three.js. Drag 3D to orbit · Select a box · Change K, R, T

04

Writing

All posts →